
Barrett Drive Systems
Eight-axis programmable grasper — 980 g, 25 mm base, totally self-contained, with serial and CAN control.
BarrettHand™
dexterous grasping
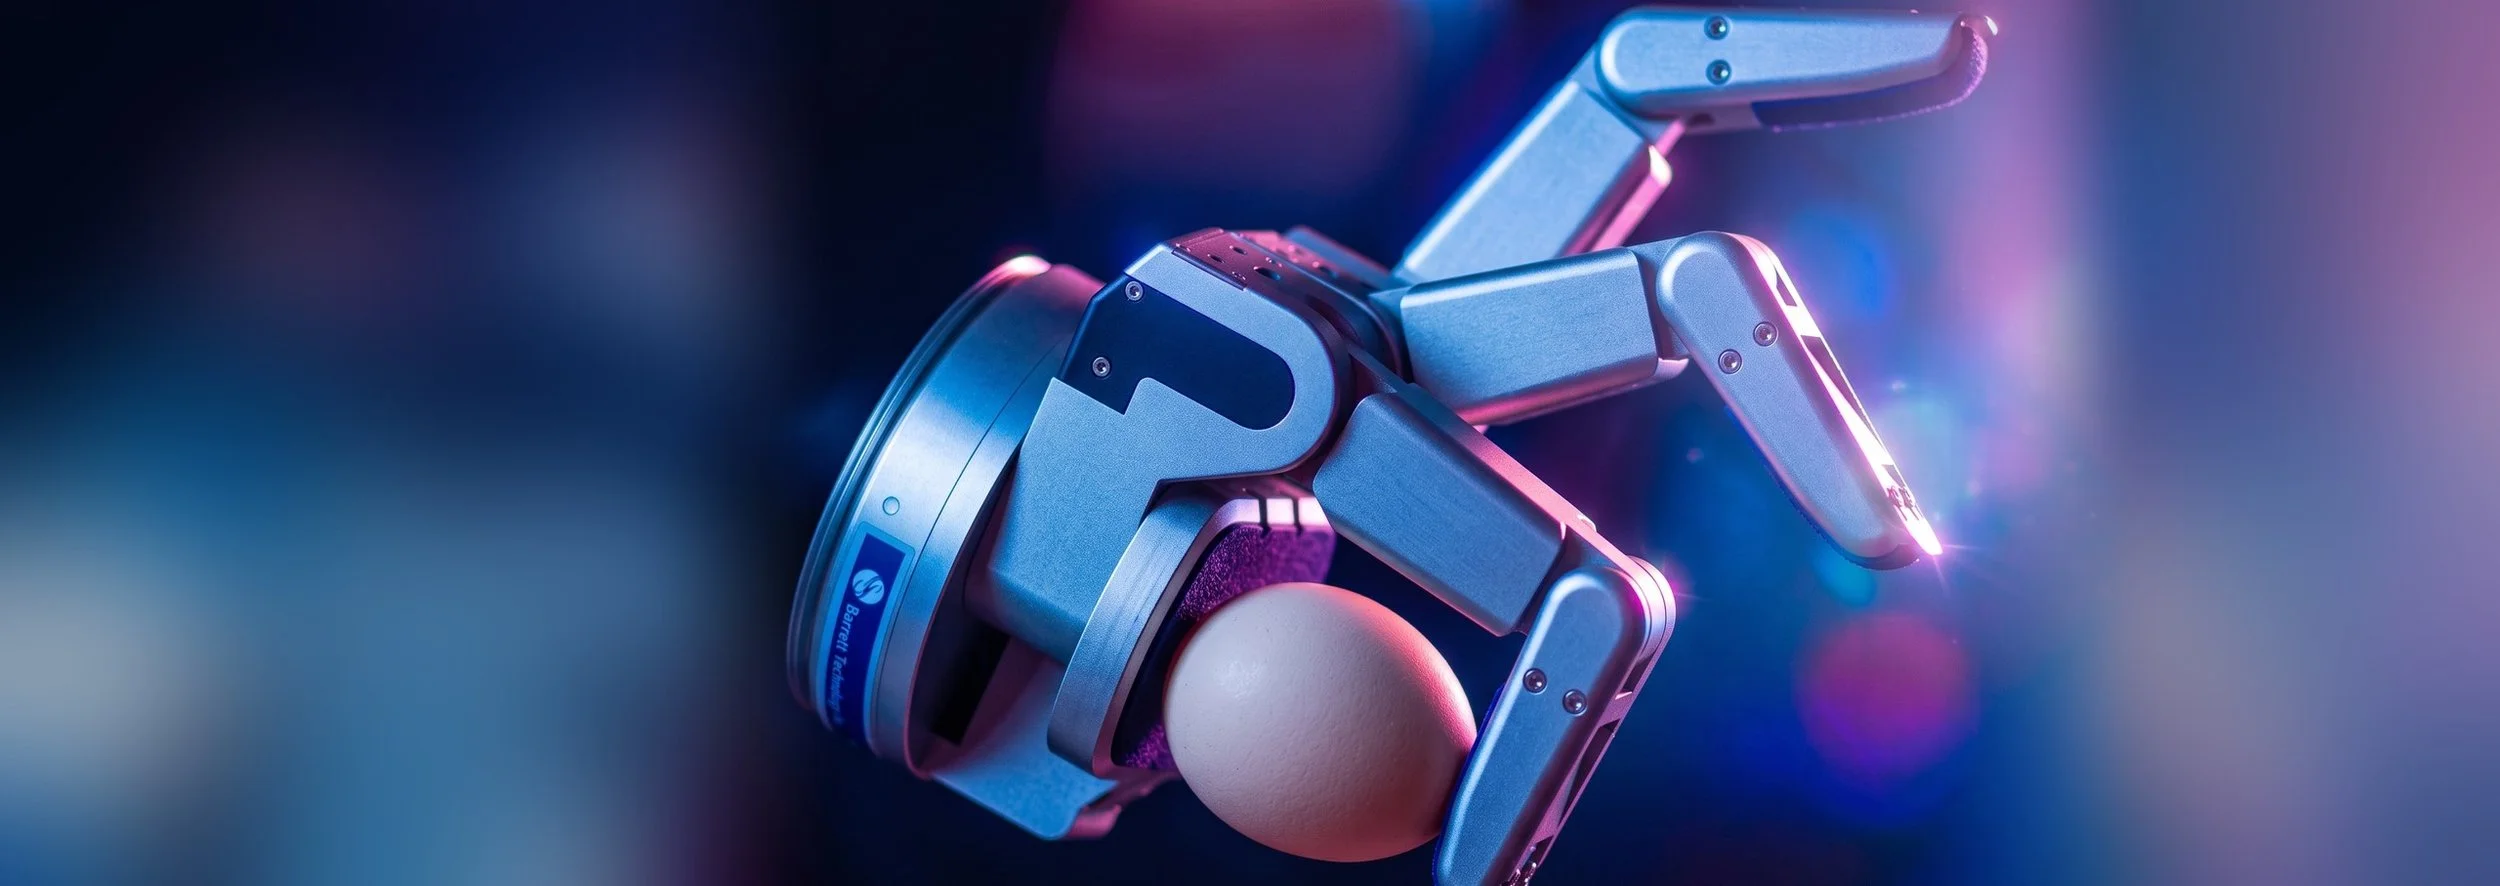
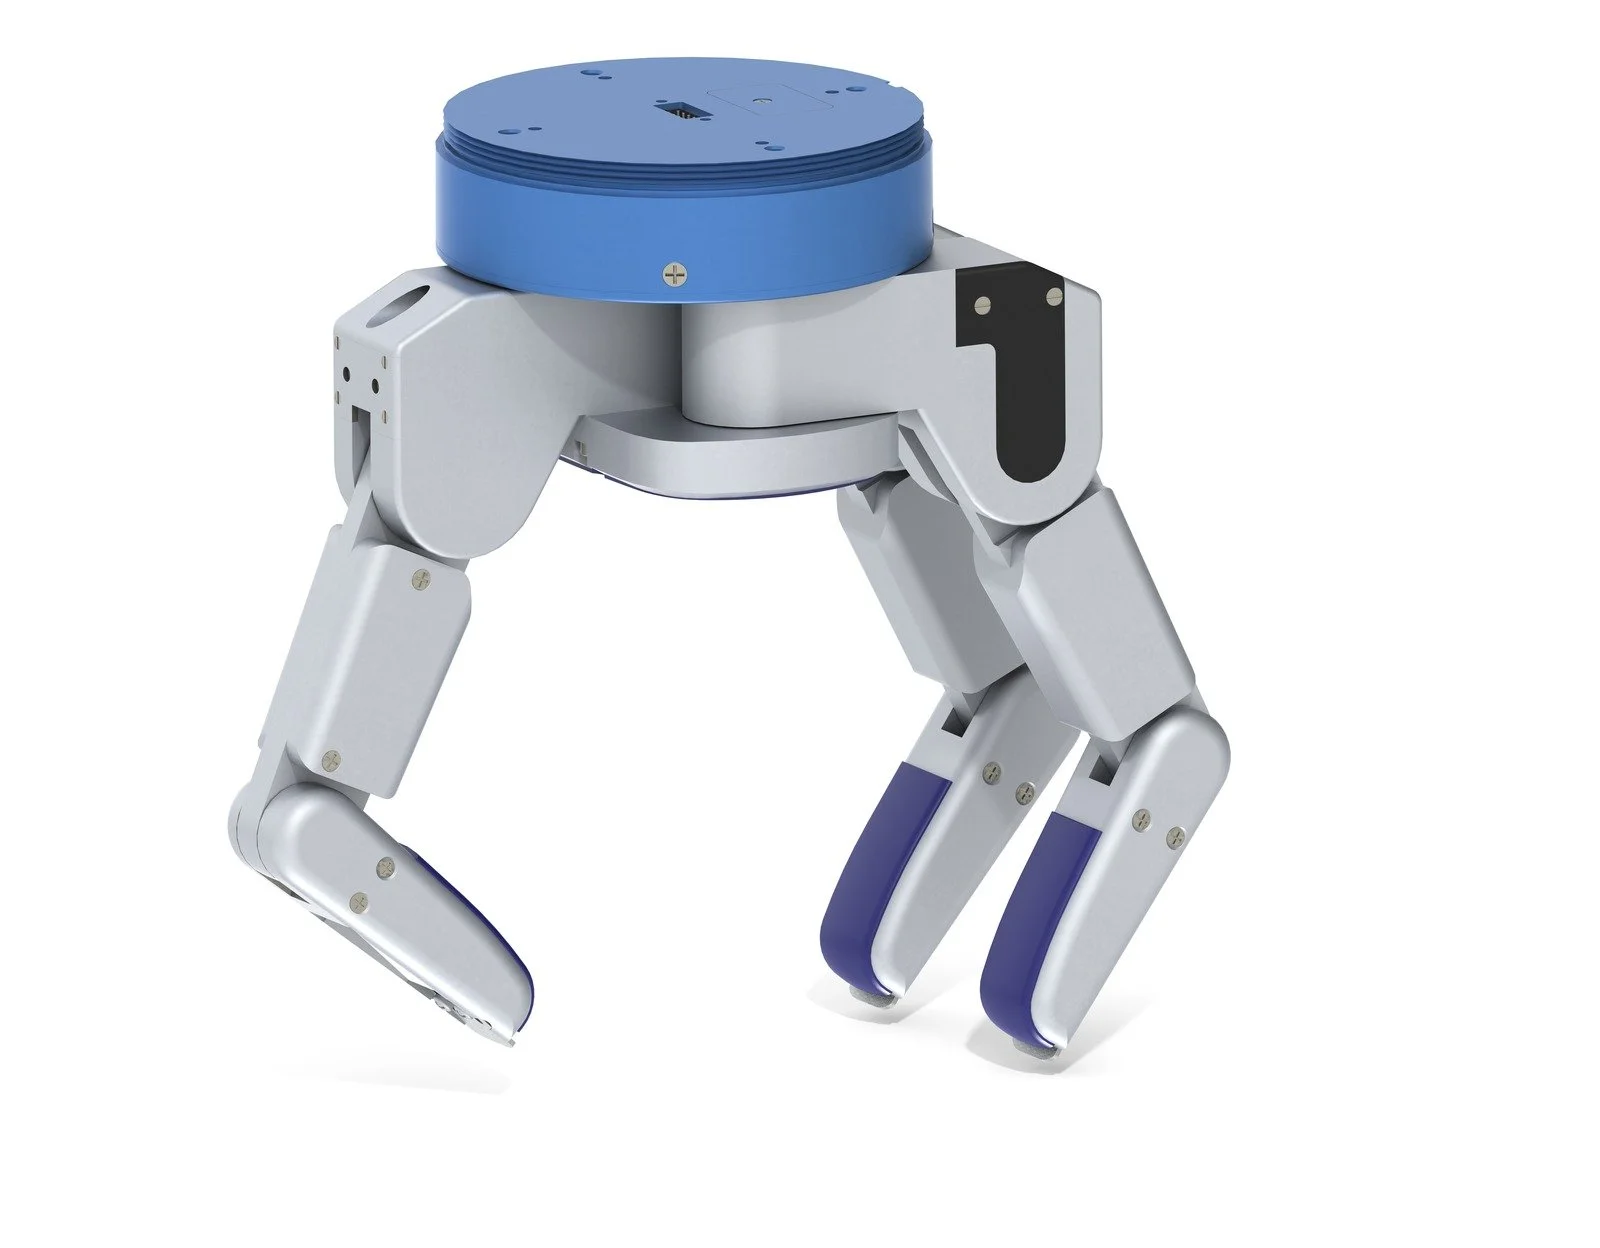
The BH8-series BarrettHand™ is an eight-axis programmable grasper that reconfigures in real time to secure objects of varying size, shape and orientation — without stopping for a tool change. At 980 grams on a 25 mm base it is entirely self-contained, communicating over industry-standard serial or high-speed CANbus.
Multi-fingered programmable grasper
The case for dexterity
Each gripper must be custom designed. Grippers require specialists to design, fabricate, and debug specially-shaped finger surfaces for each part shape and for each unique part orientation.
Unless the host arm will perpetually perform the same task, it needs an infinitely variable supply of grippers and the ability to switch between them instantly as the part shapes and orientations change. A robot arm exchanges grippers with either a turret or a tool changer. A turret is limited to switching between 2 or 3 grippers. A tool changer can handle a large number of grippers, but at the enormous costs of wasted space from storage fixtures and badly increased cycle times.
Combined with its versatile software routines, a single BarrettHand matches the functionality of an endless set of custom grippers—yet switches part/tool shapes electronically within half a second.
The BarrettHand integrates with your application by consolidating many custom gripper tools into a single smart grasper. It is shipped as a complete turn-key system.
Why buy a BarrettHand™ when parallel-jaw grippers are so cheap?
The BarrettHand™ in motion
See it in action
Tactile sensing
Outperformed 2-finger grippers on deformable objects — IEEE T-RO 2024 24,000-measurement dataset, public Learned tactile feedback for contact-rich tasks — IJRR 2022Grasp learning
Sim-to-real policy transferred to four grippers — ICRA 2021 Multi-object grasping, up to 60% fewer transfers — RA-L 2024 Multi-object grasp taxonomy — ICRA 2022Software
libbarrett — real-time C++ library pyHand — Python API and GUI ROS 2 driver pyHand installer (Windows)| Upgrade option | What it measures | Range | Resolution | Datasheet |
|---|---|---|---|---|
| Tactile Sensorspalm, fingers and fingertips | Pressure across 96 cells | 10 N/cm² | 0.01–0.02 N/cell | BH8-282 PDF |
| Fingertip Torqueone sensor per finger | Torque about the last joint | ±1 N·m | 0.04 N·m | BH8-282 PDF |
| Force/Torque Sensormounts between arm and Hand | Six-axis force and torque | ±80 N · ±2.75 N·m | 50 mN · 1.5 mN·m | F/T Sensor PDF |
| Perception Palmcameras, laser and IR range | Depth and object pose, from the palm | — | — | ROS drivers |
Extend the platform
Software and Options
Ready to add a BarrettHand?
Configurations, lead times, and quotes - we answer in one business day.